BUILDS & SYSTEMS
Robot arms, autonomous racing, embedded telemetry and legged robots. Open any project for the problem, the build and the result.
F1TENTH Autonomous Racing Stack (ROS 2)
ROS 2 Autonomous Racecar Stack in F1TENTH Gym
A hands-on ROS 2 learning implementation built on the official F1TENTH Gym simulator, progressing from safety braking (iTTC) and PID wall following to cubic spline raceline generation, pure pursuit, and multi-agent dynamic overtaking.
RESULT: 2-car overtaking at 4.0 m/s · iTTC braking under 0.4 s
Advanced Safe Load Indicator (BE Capstone)
Multi-Sensor SLI Developed on a Custom 4-Axis Scale-Model Crane
Final-year team capstone: an affordable, retrofittable Safe Load Indicator for small pick-and-carry cranes, built on a custom 4-axis crane test rig with load, angle, extension, outrigger and IMU sensing, ESP32 FreeRTOS firmware and a live dashboard.
RESULT: Rig running end to end · safety alarms in hardware testing
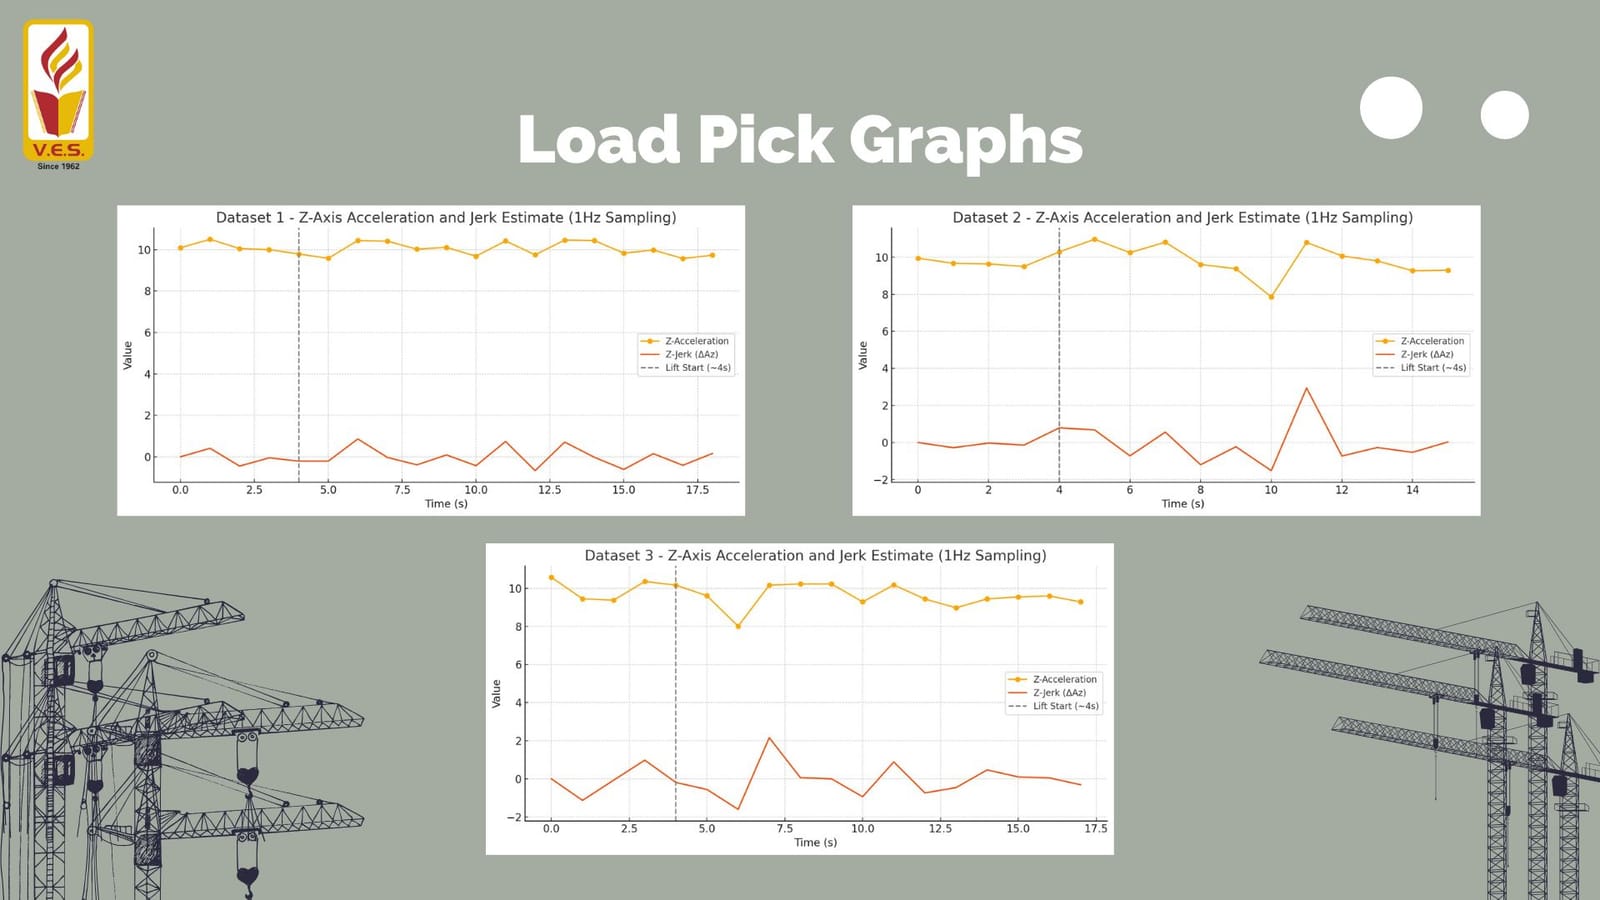
Crane Health & Operator Monitoring System
Two-Module IMU Telemetry System, Field-Tested on an Escorts F15 Farana Crane
A dual-module crane monitoring system using MPU6050 IMU and ESP-NOW to track boom orientation, jerk magnitude, and lift duration for unsafe operation alerts and lift profile reconstruction.
RESULT: Field-tested on an Escorts F15 Farana crane
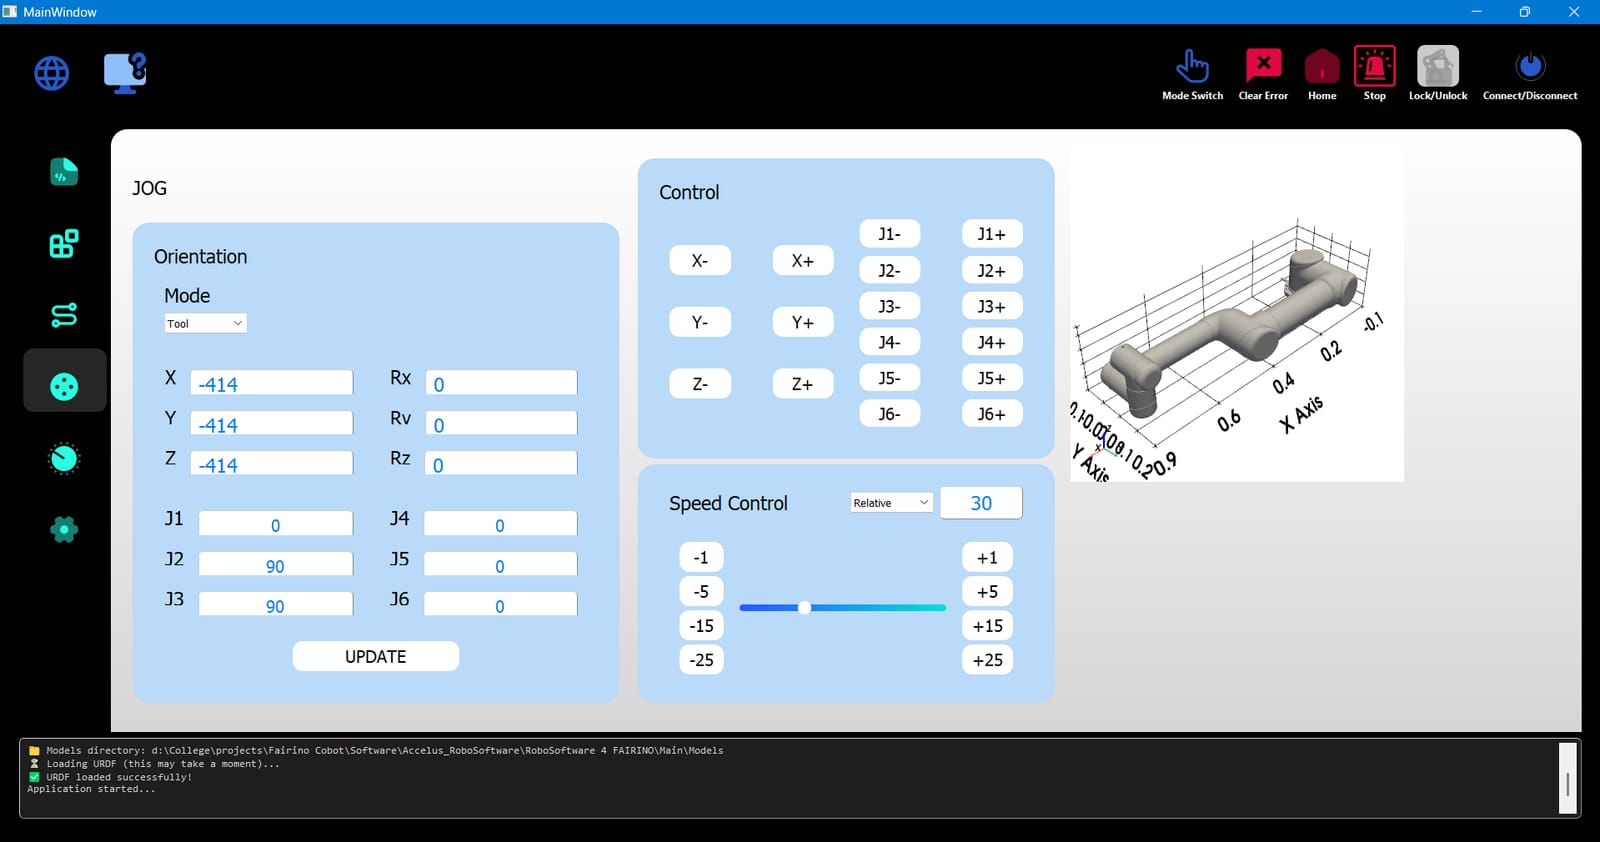
6-DOF Robotic Control Software Platform (Accelus Robotics)
Desktop-Based Control & Automation Platform for Industrial Arm & FAIRINO Cobot
Desktop control application built using Python and PyQt5 integrating robot SDKs, URDF/PyVista 3D visualization, and Blockly visual programming for industrial robot automation.
RESULT: Validated on a 6-DOF arm and a FAIRINO cobot
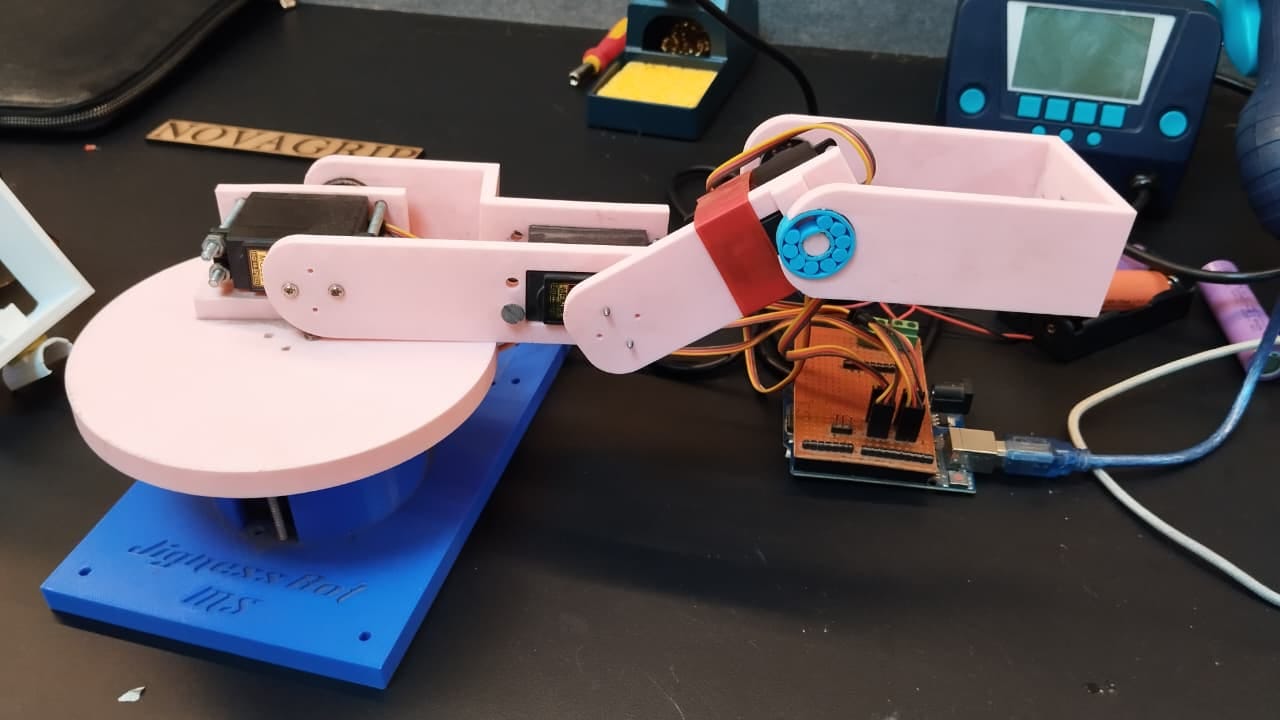
4-DOF Computer Vision Gesture-Controlled Robotic Arm
Real-Time Hand-Gesture Tracking & Joint Angle Mapping Manipulator
A 4-DOF 3D-printed robotic arm controlled in real-time by mapping human arm joint angles tracked via computer vision (OpenCV & MediaPipe) over USB serial.
RESULT: Real-time gesture control over USB serial
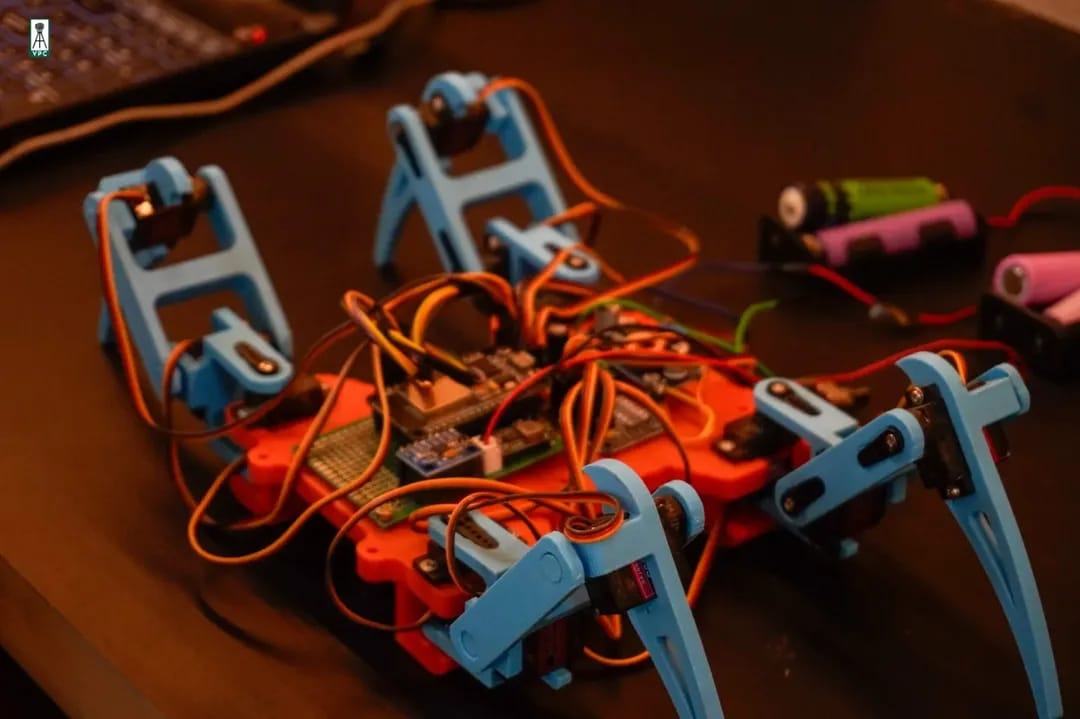
12-DOF Quadruped 'Spidy' Robot
3D-Printed Quadruped with ESP32 Firmware, a PySide6 Control App and MuJoCo Simulation
A 12-servo quadruped on a custom 3D-printed frame with ESP32 firmware, a PySide6 control and calibration app, and a MuJoCo model for gait development. It stands and sits on hardware; crawling works in simulation.
RESULT: Stands and sits on hardware · crawl works in sim · paused on servo torque
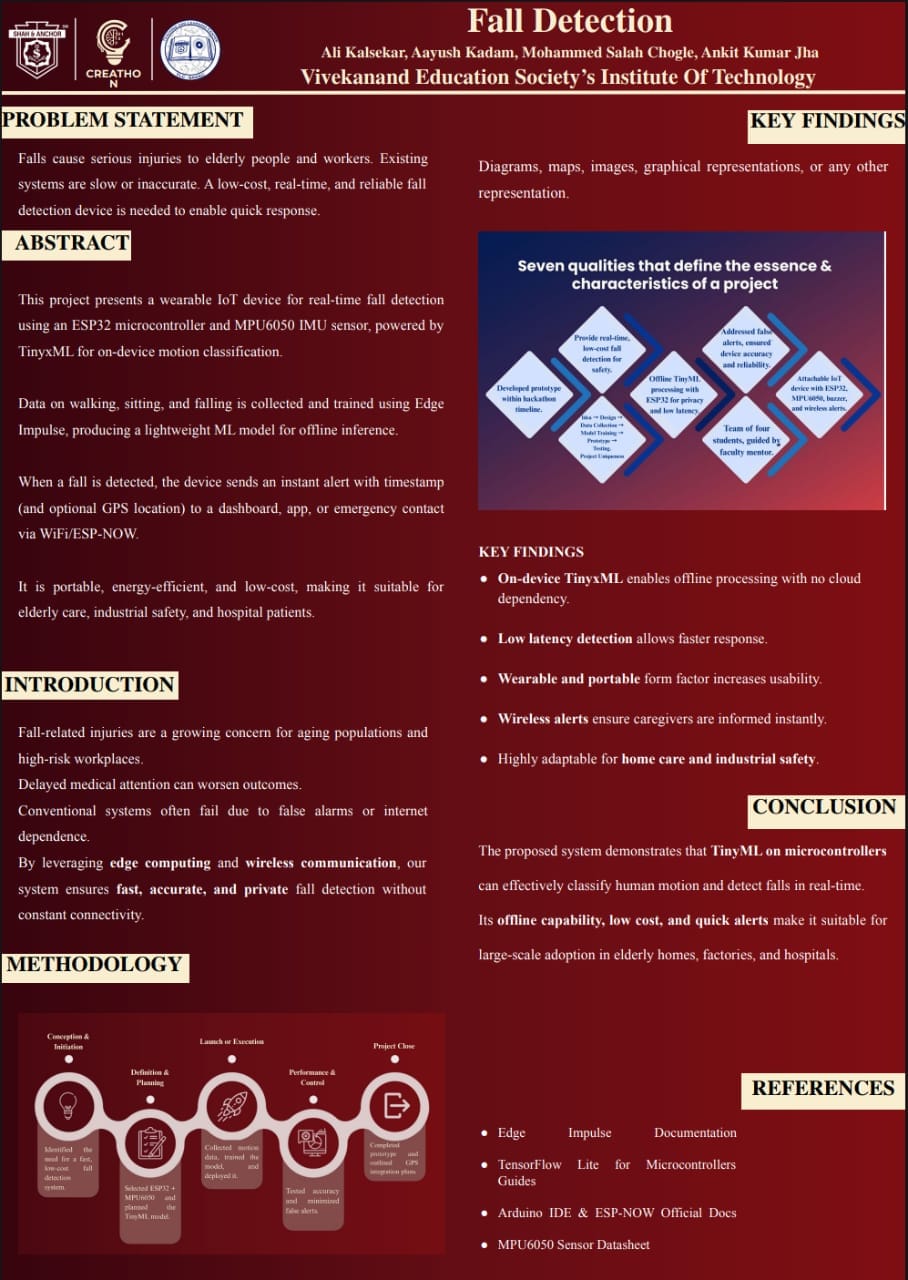
Helmet/Belt-Mounted Fall Detection & SOS Alert System
Real-Time Fall Detection, Impact Verification & Remote Blynk IoT Alerting System
A wearable safety device for workers, bikers, and elderly individuals featuring MPU6050 fall detection, impact + stillness verification, ESP-NOW wireless transmission, and Blynk IoT remote alerting.
RESULT: Drop → impact → stillness check to cut false alarms
Micro Inverted Pendulum (Cart-Pole System)
Benchtop Balancing System with Cascade PID & Encoders
A cart-pole balancing system on a linear rail driven by an ESP32, using quadrature encoders and dynamic feedback loops for system stabilization.
RESULT: Balanced with tuned cascade PID
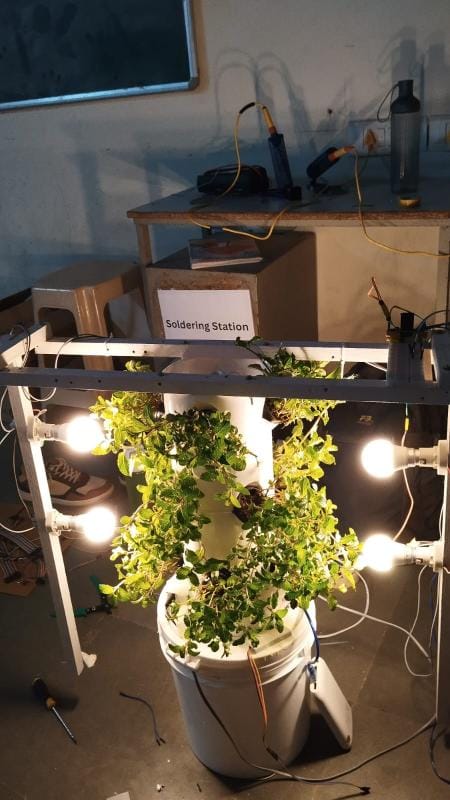
Automated IoT Aeroponics Smart Tower
Soil-Less Farming System with Automated Nutrient & pH Regulation
An automated soil-less farming tower with environmental sensors, ESP32 telemetry and solenoid-controlled nutrient dosing.
RESULT: 2nd place, VES HACK-IT 30-hour hackathon
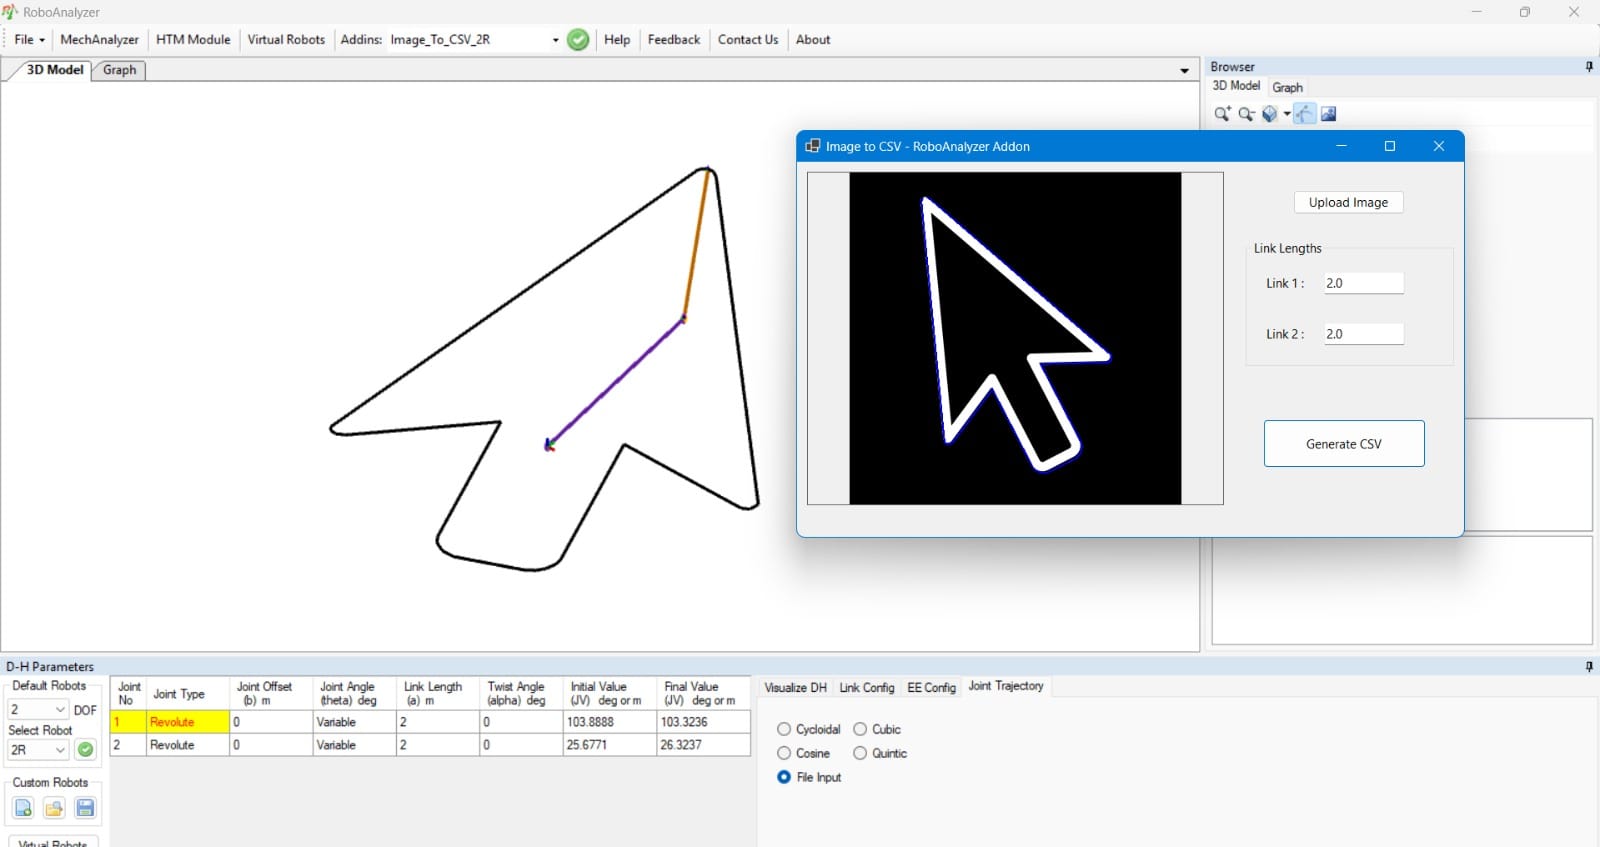
RoboAnalyzer Open-Source Add-On Suite
Image-to-CSV Trajectory Generator, Jacobian Visualizer & AI Chatbot
Tools that extend RoboAnalyzer: hand-drawn path extraction with 2-link IK, a Jacobian visualizer and an AI chatbot assistant.
RESULT: 1st place nationally at IIT Delhi
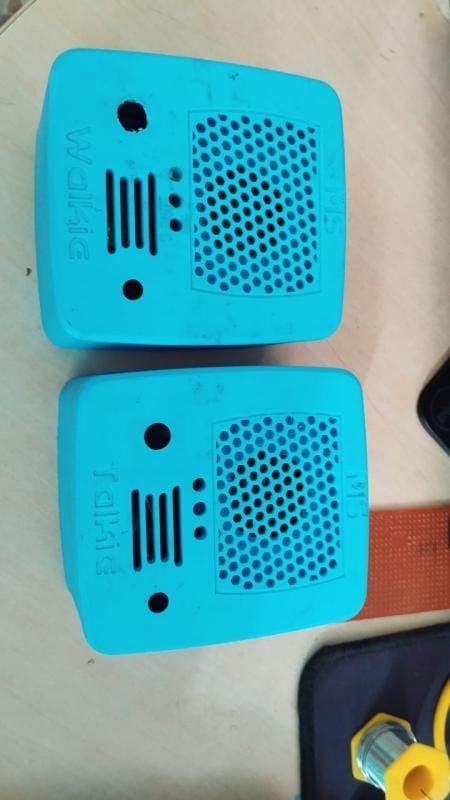
ESP32 Low-Latency ESP-NOW Walkie-Talkie
Peer-to-Peer Standalone Audio Streaming System
A half-duplex, routerless walkie-talkie using two ESP32s, I2S audio hardware, IMA-ADPCM compression, and ESP-NOW protocol.
RESULT: Routerless voice link, ~10–15 m indoors
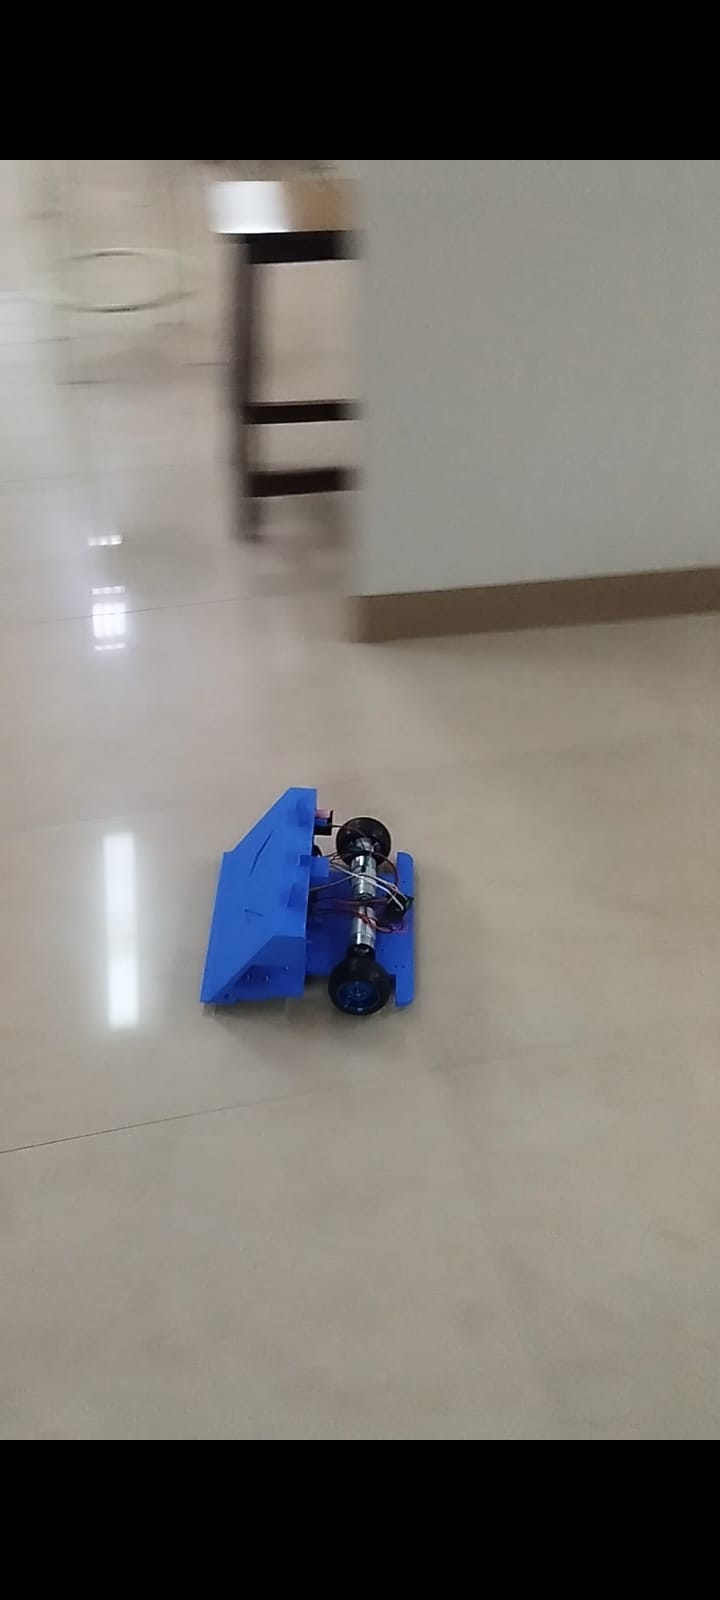
Custom RF Wireless RoboWar Combat Bot
Heavy-Duty Combat Robot with Custom Laptop Xbox Controller Protocol
A high-power combat robot built with an NRF24L01 wireless link accepting low-latency Xbox controller commands bridged from a host laptop.
RESULT: Laptop-bridged Xbox control over NRF24L01
Advanced Safe Load Indicator (BE Capstone)
Multi-Sensor SLI Developed on a Custom 4-Axis Scale-Model Crane
RESULT: Rig running end to end · safety alarms in hardware testing
Low-capacity pick-and-carry cranes lack accurate, affordable load monitoring, unlike larger cranes with factory-fitted rated capacity indicators, which raises the risk of overloading and tipping.
An ESP32 running FreeRTOS reads three AS5600 magnetic encoders (swing, boom, telescope), an MPU6050 on the boom, an HX711 load cell and four outrigger FSRs, and drives the axes through an Arduino Mega + RAMPS (three steppers) and an N20 winch. A FastAPI backend logs every session to CSV and streams it to a React dashboard showing load %, boom geometry, outrigger loads and motor controls.
OVERVIEW
Small truck-mounted pick-and-carry cranes rarely have a safe load indicator, so operators work from experience alone. This BE capstone (team of three, VESIT) builds one, together with a custom scale-model crane to develop it on: swing, boom lift, telescopic extension and a winch, each motor-driven with sensor feedback. It follows my 2025 crane inertial-analysis project, which was tested on a real crane; this system is developed and validated on the rig. Status (Oct 2026): the full stack runs on hardware. A 34-minute logged session streamed swing, boom angle, extension, outrigger loads, IMU data and live load (up to 83.5% of the 5 kg limit) to the dashboard. Load-chart alarms, a latched E-stop and a dead-man stop are implemented and unit tested on a development branch but not yet proven on hardware. Anti-sway and tipping prediction come next.