BUILDS & SYSTEMS
Robot arms, autonomous racing, embedded telemetry and legged robots. Open any project for the problem, the build and the result.
F1TENTH Autonomous Racing Stack (ROS 2)
ROS 2 Autonomous Racecar Stack in F1TENTH Gym
A hands-on ROS 2 learning implementation built on the official F1TENTH Gym simulator, progressing from safety braking (iTTC) and PID wall following to cubic spline raceline generation, pure pursuit, and multi-agent dynamic overtaking.
RESULT: 2-car overtaking at 4.0 m/s · iTTC braking under 0.4 s
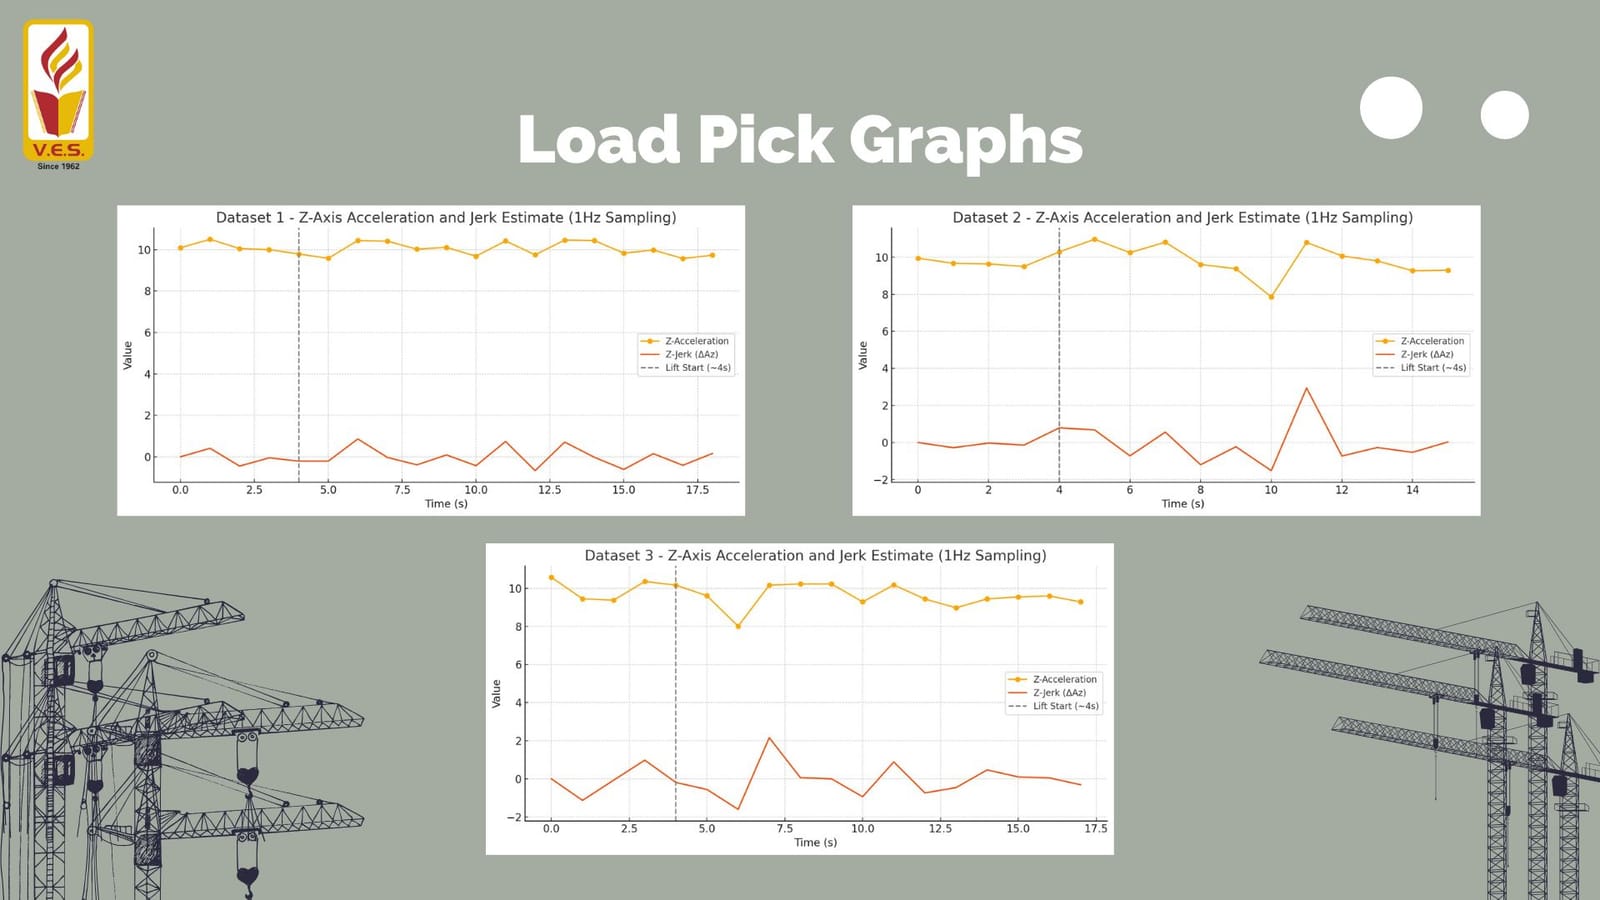
Crane Health & Operator Monitoring System
Two-Module IMU Telemetry System, Field-Tested on an Escorts F15 Farana Crane
A dual-module crane monitoring system using MPU6050 IMU and ESP-NOW to track boom orientation, jerk magnitude, and lift duration for unsafe operation alerts and lift profile reconstruction.
RESULT: Field-tested on an Escorts F15 Farana crane
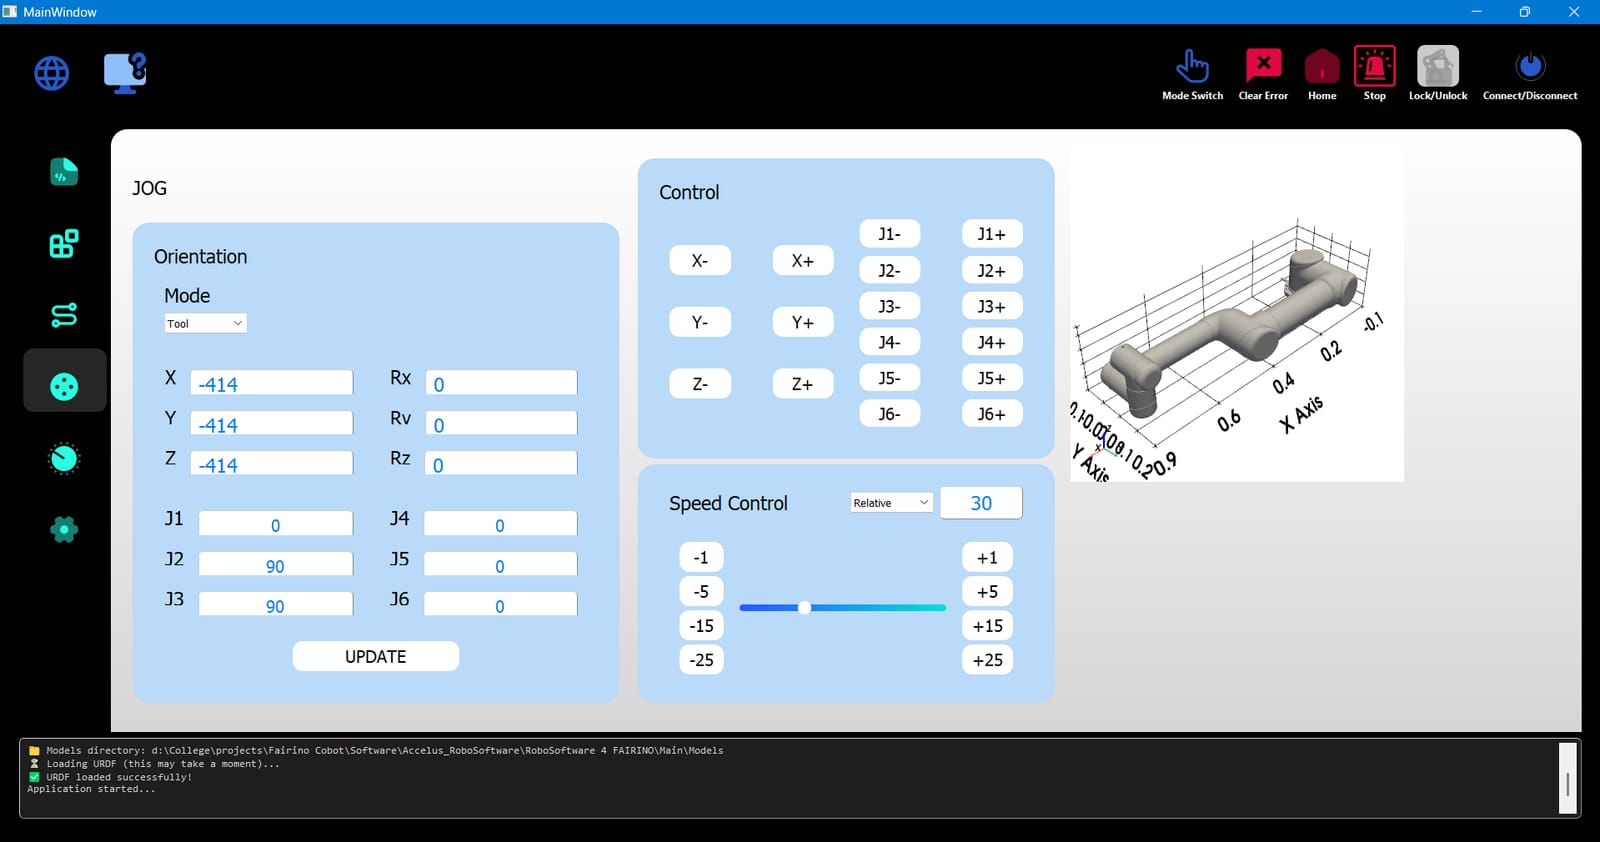
6-DOF Robotic Control Software Platform (Accelus Robotics)
Desktop-Based Control & Automation Platform for Industrial Arm & FAIRINO Cobot
Desktop control application built using Python and PyQt5 integrating robot SDKs, URDF/PyVista 3D visualization, and Blockly visual programming for industrial robot automation.
RESULT: Validated on a 6-DOF arm and a FAIRINO cobot
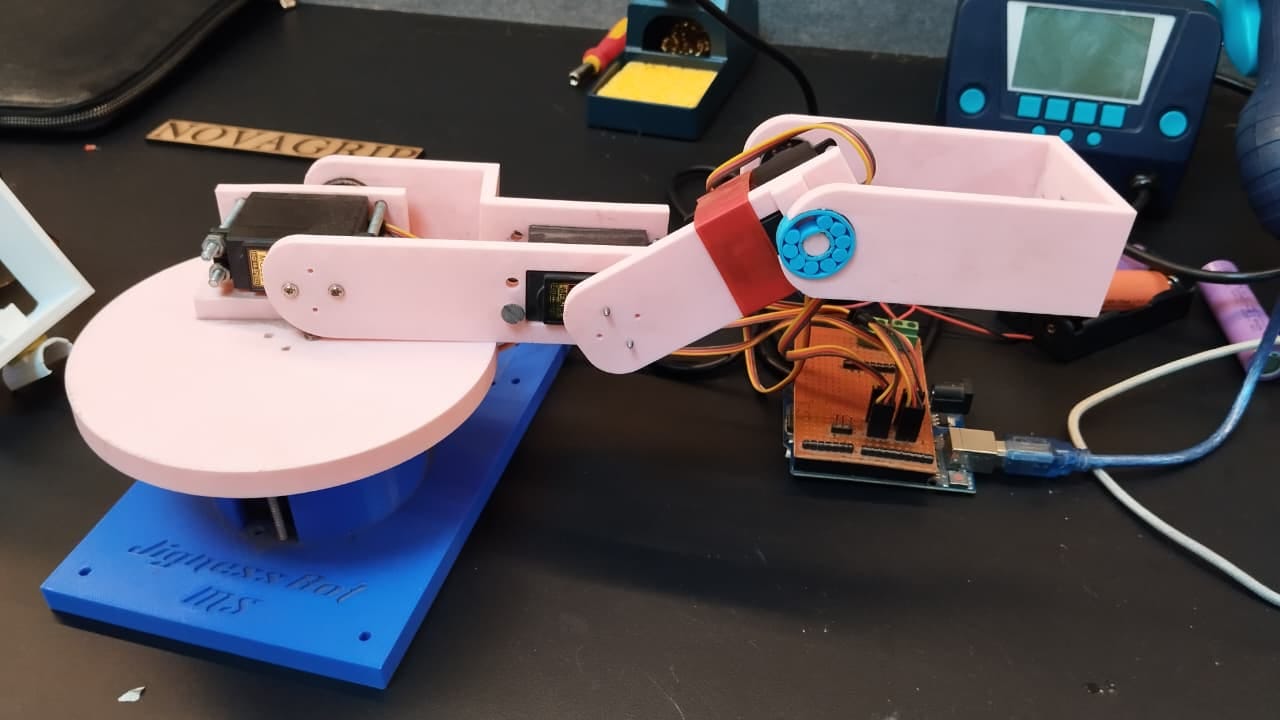
4-DOF Computer Vision Gesture-Controlled Robotic Arm
Real-Time Hand-Gesture Tracking & Joint Angle Mapping Manipulator
A 4-DOF 3D-printed robotic arm controlled in real-time by mapping human arm joint angles tracked via computer vision (OpenCV & MediaPipe) over USB serial.
RESULT: Real-time gesture control over USB serial
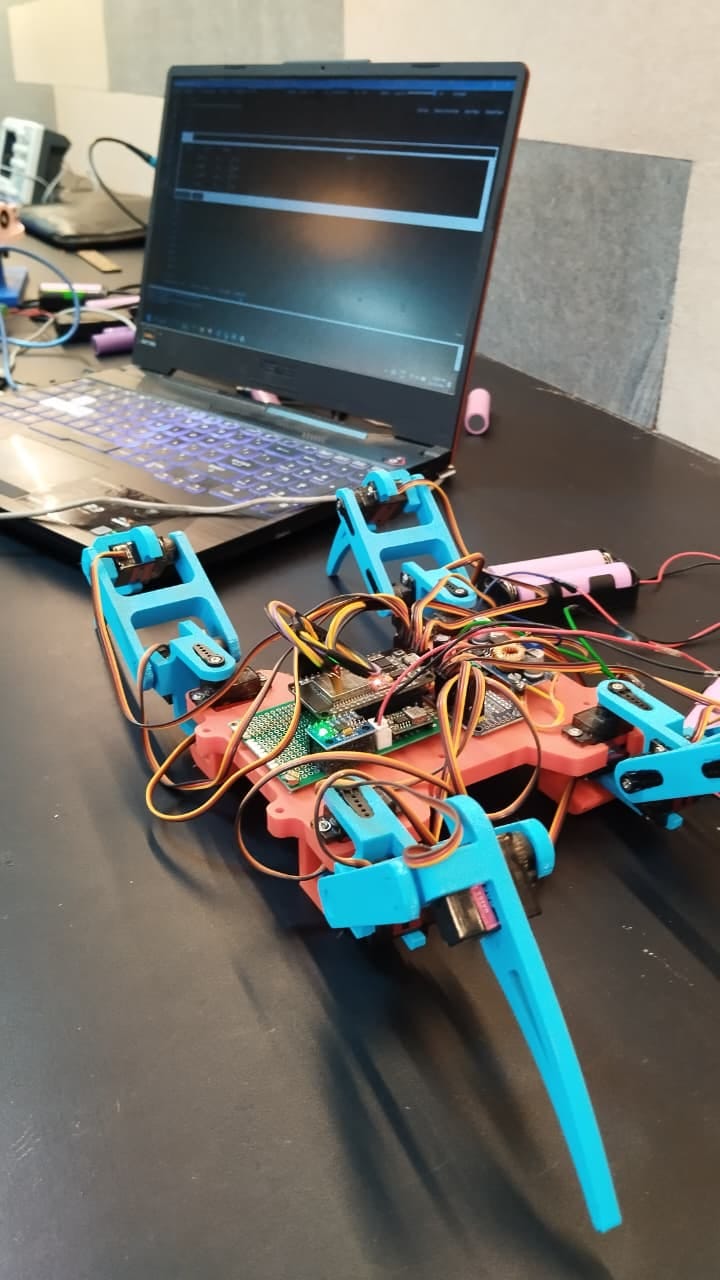
12-DOF Quadruped 'Spidy' Robot
Custom 3D-Printed 4-Legged Walking Platform with Servo Control
A 12-servo 4-legged walking robot built on a custom 3D-printed frame, featuring ESP32 control and a PCA9685 driver module.
RESULT: Frame, power and wiring done · gait in development
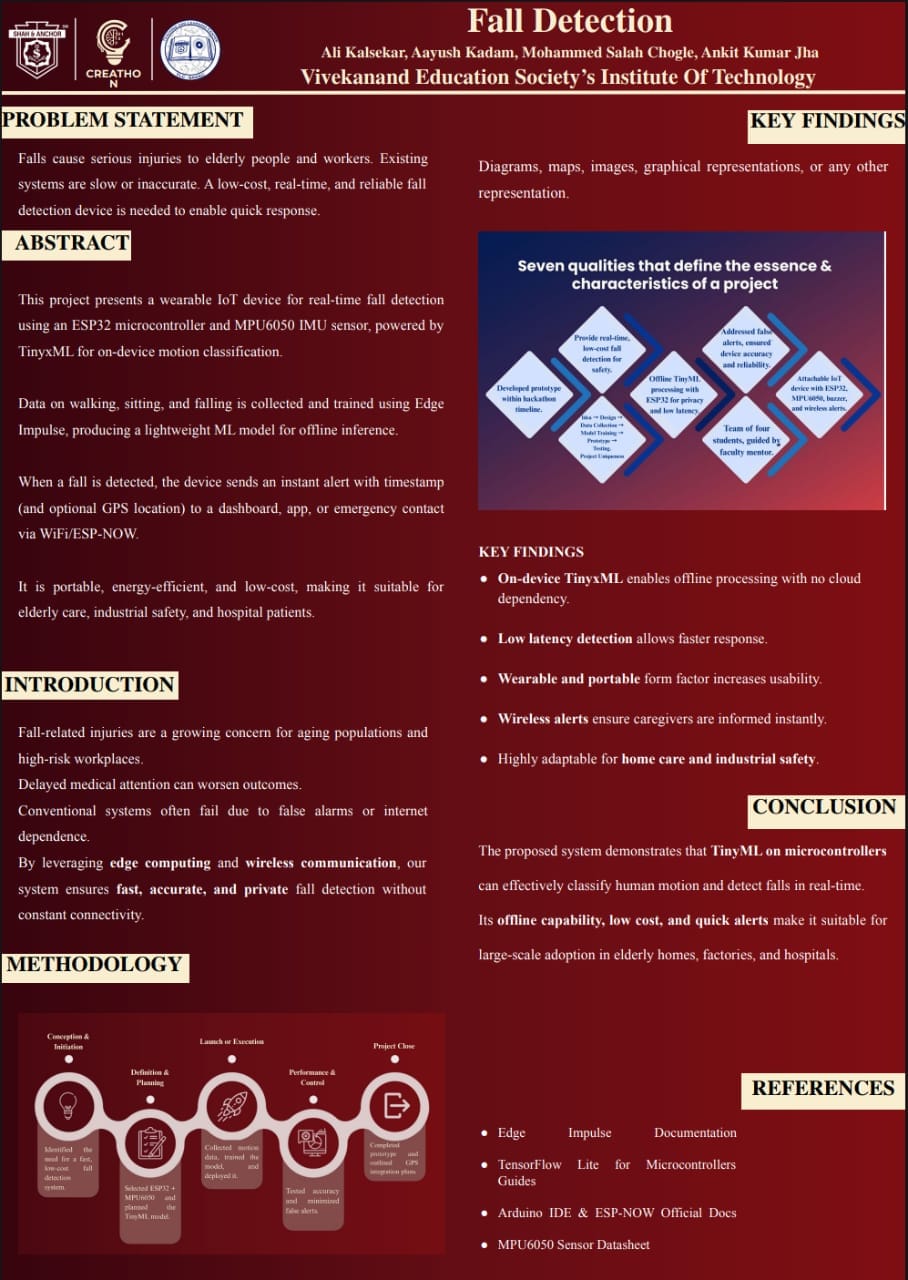
Helmet/Belt-Mounted Fall Detection & SOS Alert System
Real-Time Fall Detection, Impact Verification & Remote Blynk IoT Alerting System
A wearable safety device for workers, bikers, and elderly individuals featuring MPU6050 fall detection, impact + stillness verification, ESP-NOW wireless transmission, and Blynk IoT remote alerting.
RESULT: Drop → impact → stillness check to cut false alarms
Micro Inverted Pendulum (Cart-Pole System)
Benchtop Balancing System with Cascade PID & Encoders
A cart-pole balancing system on a linear rail driven by an ESP32, using quadrature encoders and dynamic feedback loops for system stabilization.
RESULT: Balanced with cascade PID · LQR in progress
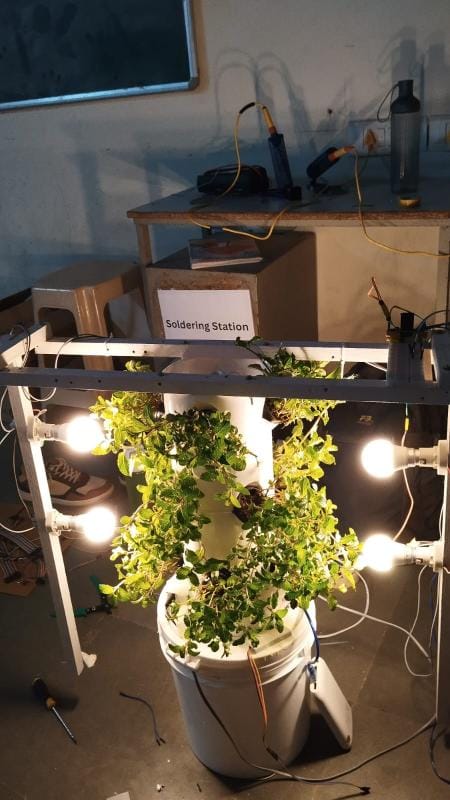
Automated IoT Aeroponics Smart Tower
Soil-Less Farming System with Automated Nutrient & pH Regulation
An automated soil-less farming tower with environmental sensors, ESP32 telemetry and solenoid-controlled nutrient dosing.
RESULT: 2nd place, VES HACK-IT 30-hour hackathon
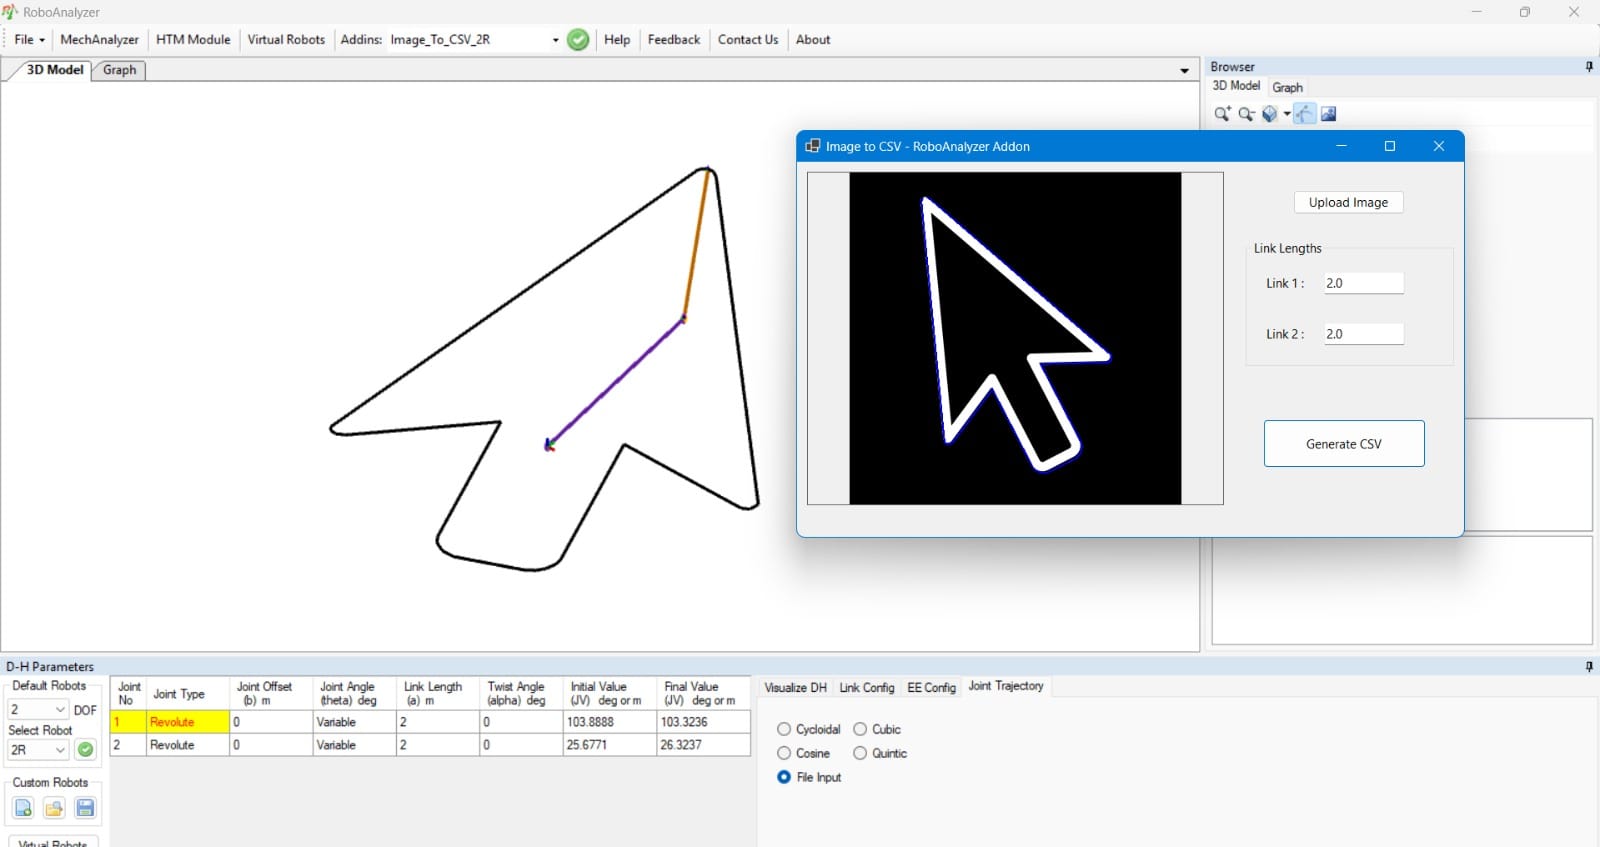
RoboAnalyzer Open-Source Add-On Suite
Image-to-CSV Trajectory Generator, Jacobian Visualizer & AI Chatbot
Tools that extend RoboAnalyzer: hand-drawn path extraction with 2-link IK, a Jacobian visualizer and an AI chatbot assistant.
RESULT: 1st place nationally at IIT Delhi
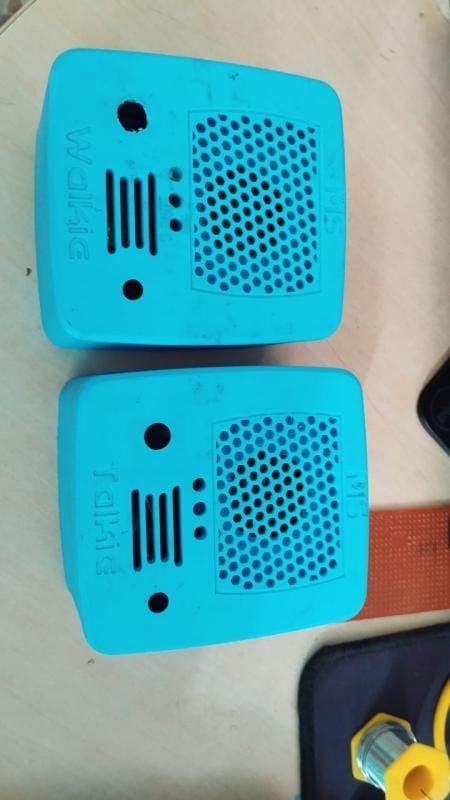
ESP32 Low-Latency ESP-NOW Walkie-Talkie
Peer-to-Peer Standalone Audio Streaming System
A half-duplex, routerless walkie-talkie using two ESP32s, I2S audio hardware, IMA-ADPCM compression, and ESP-NOW protocol.
RESULT: Routerless voice link, ~10–15 m indoors
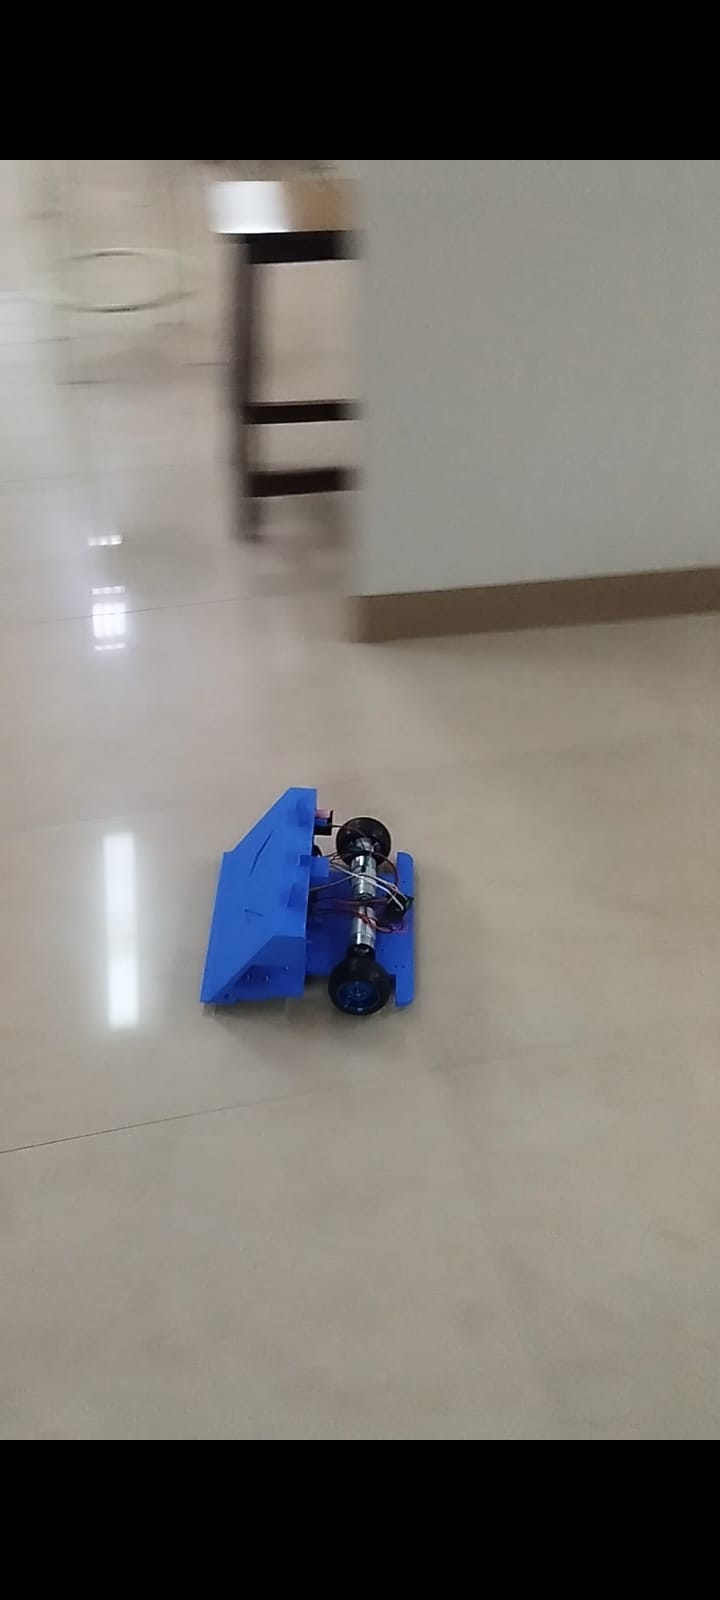
Custom RF Wireless RoboWar Combat Bot
Heavy-Duty Combat Robot with Custom Laptop Xbox Controller Protocol
A high-power combat robot built with an NRF24L01 wireless link accepting low-latency Xbox controller commands bridged from a host laptop.
RESULT: Laptop-bridged Xbox control over NRF24L01
Micro Inverted Pendulum (Cart-Pole System)
Benchtop Balancing System with Cascade PID & Encoders
RESULT: Balanced with cascade PID · LQR in progress
An inverted pendulum is unstable and non-linear, so it needs fast state feedback and well-tuned control to stay upright.
Implemented cascade PID control loops on an ESP32 reading optical encoder signals to dynamically actuate the cart carriage along a linear rail, with LQR optimal control implementation in development.
OVERVIEW
A classic inverted-pendulum benchmark, built and balanced with two feedback loops. The ESP32 reads encoders on the cart and pole and runs the balancing loop in real time on a linear rail.